Project showcase
What teams built
Every project built at the Physical AI Sprint — a one-day hackathon alongside Actuate SF, hosted by Nebius with NVIDIA, Antioch, and Toloka.

404team work
Teleoperation of so-101 plus controlling follower arm in the simulation from the leader arm in the real world
Back Online
Factory SRE is a mobile robotic first responder for factory downtime.
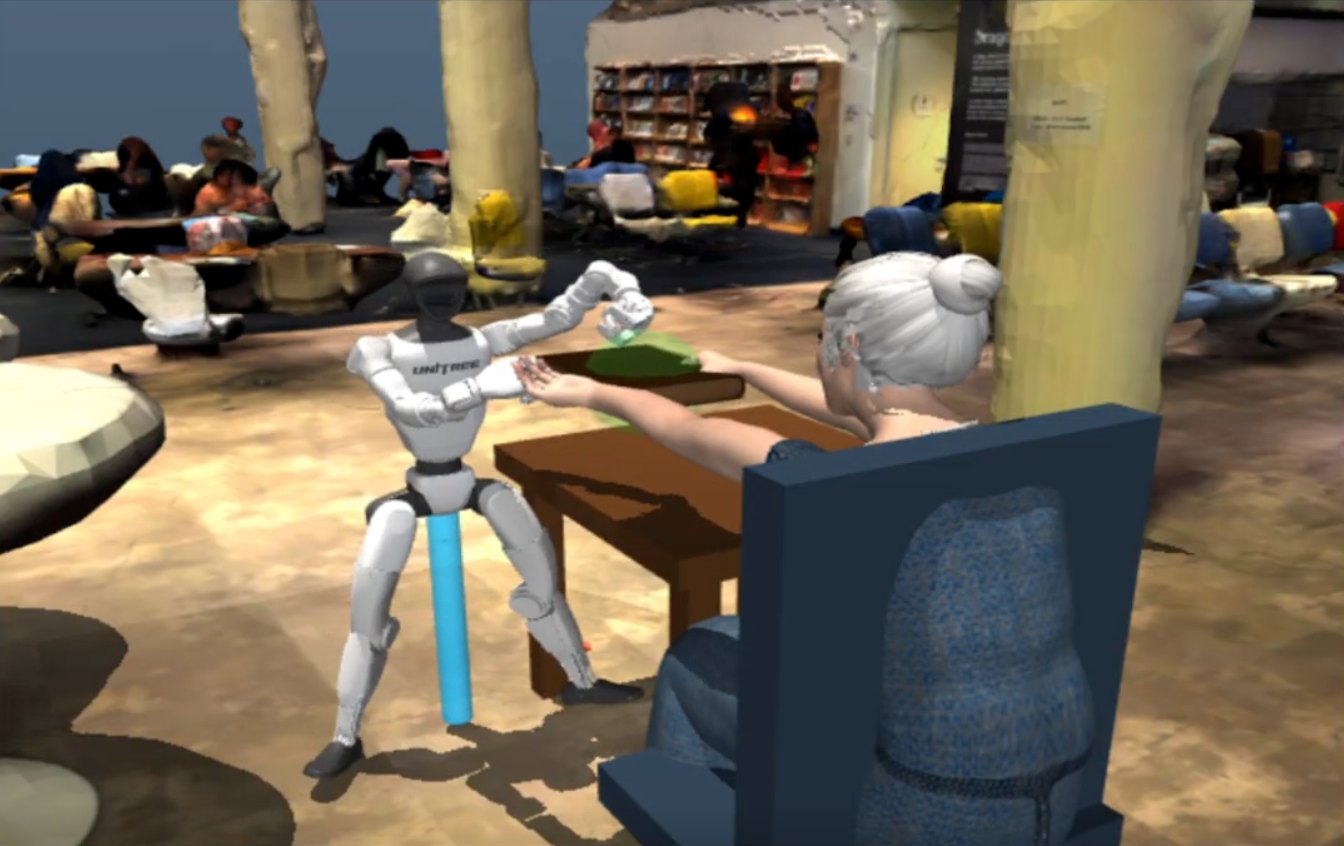
Bruno - the Librarian
An autonomous librarian that helps human staff manage libraries, retrieves requested books from shelves, and safely hands them to people.

Collaborative Reference Frames For Assistive Robotics
Using Meta Glasses vision stream combined with an actuator camera to build corrective prompts for a VLA.
Desk Duster
Our project cleans desks.
Edie Sees You
Edie is a physical AI companion who sees what you're doing and responds in real time.
Fastloop
fastloop is a physical ai control plane for authoring robot tasks in a 3d digital twin and running the same versioned contract through simulation and a real so-101.

Humanoid Yoga Instructor
Yoga is thousands of years old, but in the last decade it's gone mainstream in the West.

NemoCode
Connect your coding agent to NVIDIA Nemotron and Cosmos on Nebius Token Factory — one install, four harnesses, config-free.
 1 member
Physical AI Perception-Reasoning-Action Pipeline for a Robotic Arm
Built and hardware-verified a SO-ARM101 control stack: real-time object detection via webcam (OpenCV) with tuned color/contour filtering, camera-to-robot coordinate calibration using forward
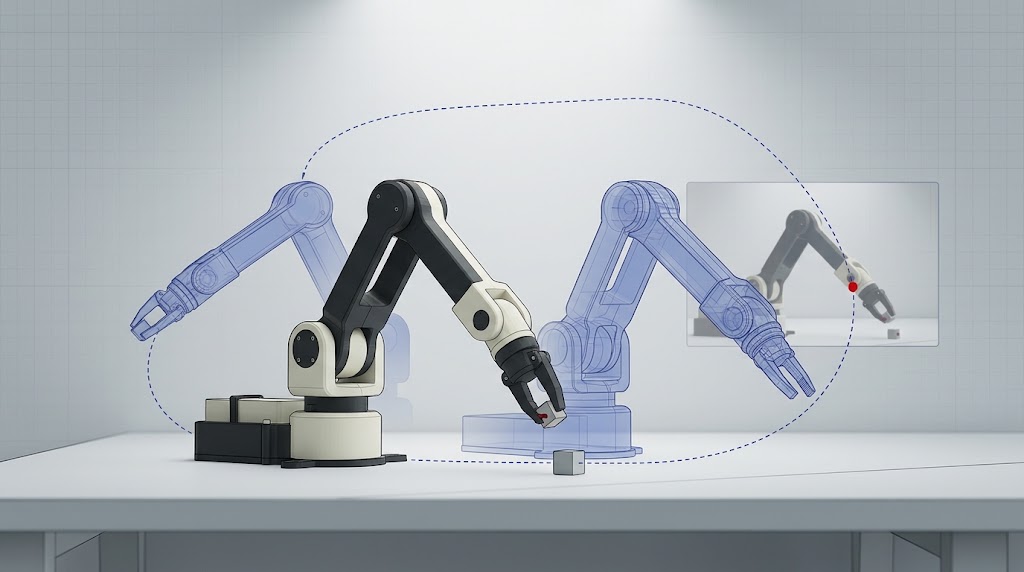
REFLECT Real-world Failure-Led Embodied Continual Training
Most robot policies are trained once, deployed once, and frozen — when reality diverges from simulation, the loop stops.
Robot skills graph
A way to track skills and attempts for replay and learning
SAFFRON - procedural saffron harvesting cell (reach verified, grasp not yet)
Saffron is the most expensive crop on earth: a kilogram is ~150,000 crocus flowers, each hand-picked for exactly three red stigma threads.

The first experiment
We were trying to get the arm move the object from one place to another.

Tubot
Identifying and picking tubes.
V9 Max
ONCE — show a robot once.

Within Reach
Within Reach An assistive robotic system for people with limited upper-body mobility.
Nothing matches
Try a different search term or clear the track filter.